FLOWER D3: the current approved FLOWER design
Written 2026-11-17. This is part of the V7 robot. Sources: stages/D3_build_package_2026-11-17.md and the D3, D3b and D3c sections of stages/V6_WORKORDER.md. Nothing here is built yet. All numbers come from CAD meshes and offline checks, not from a real robot.
The idea in plain words
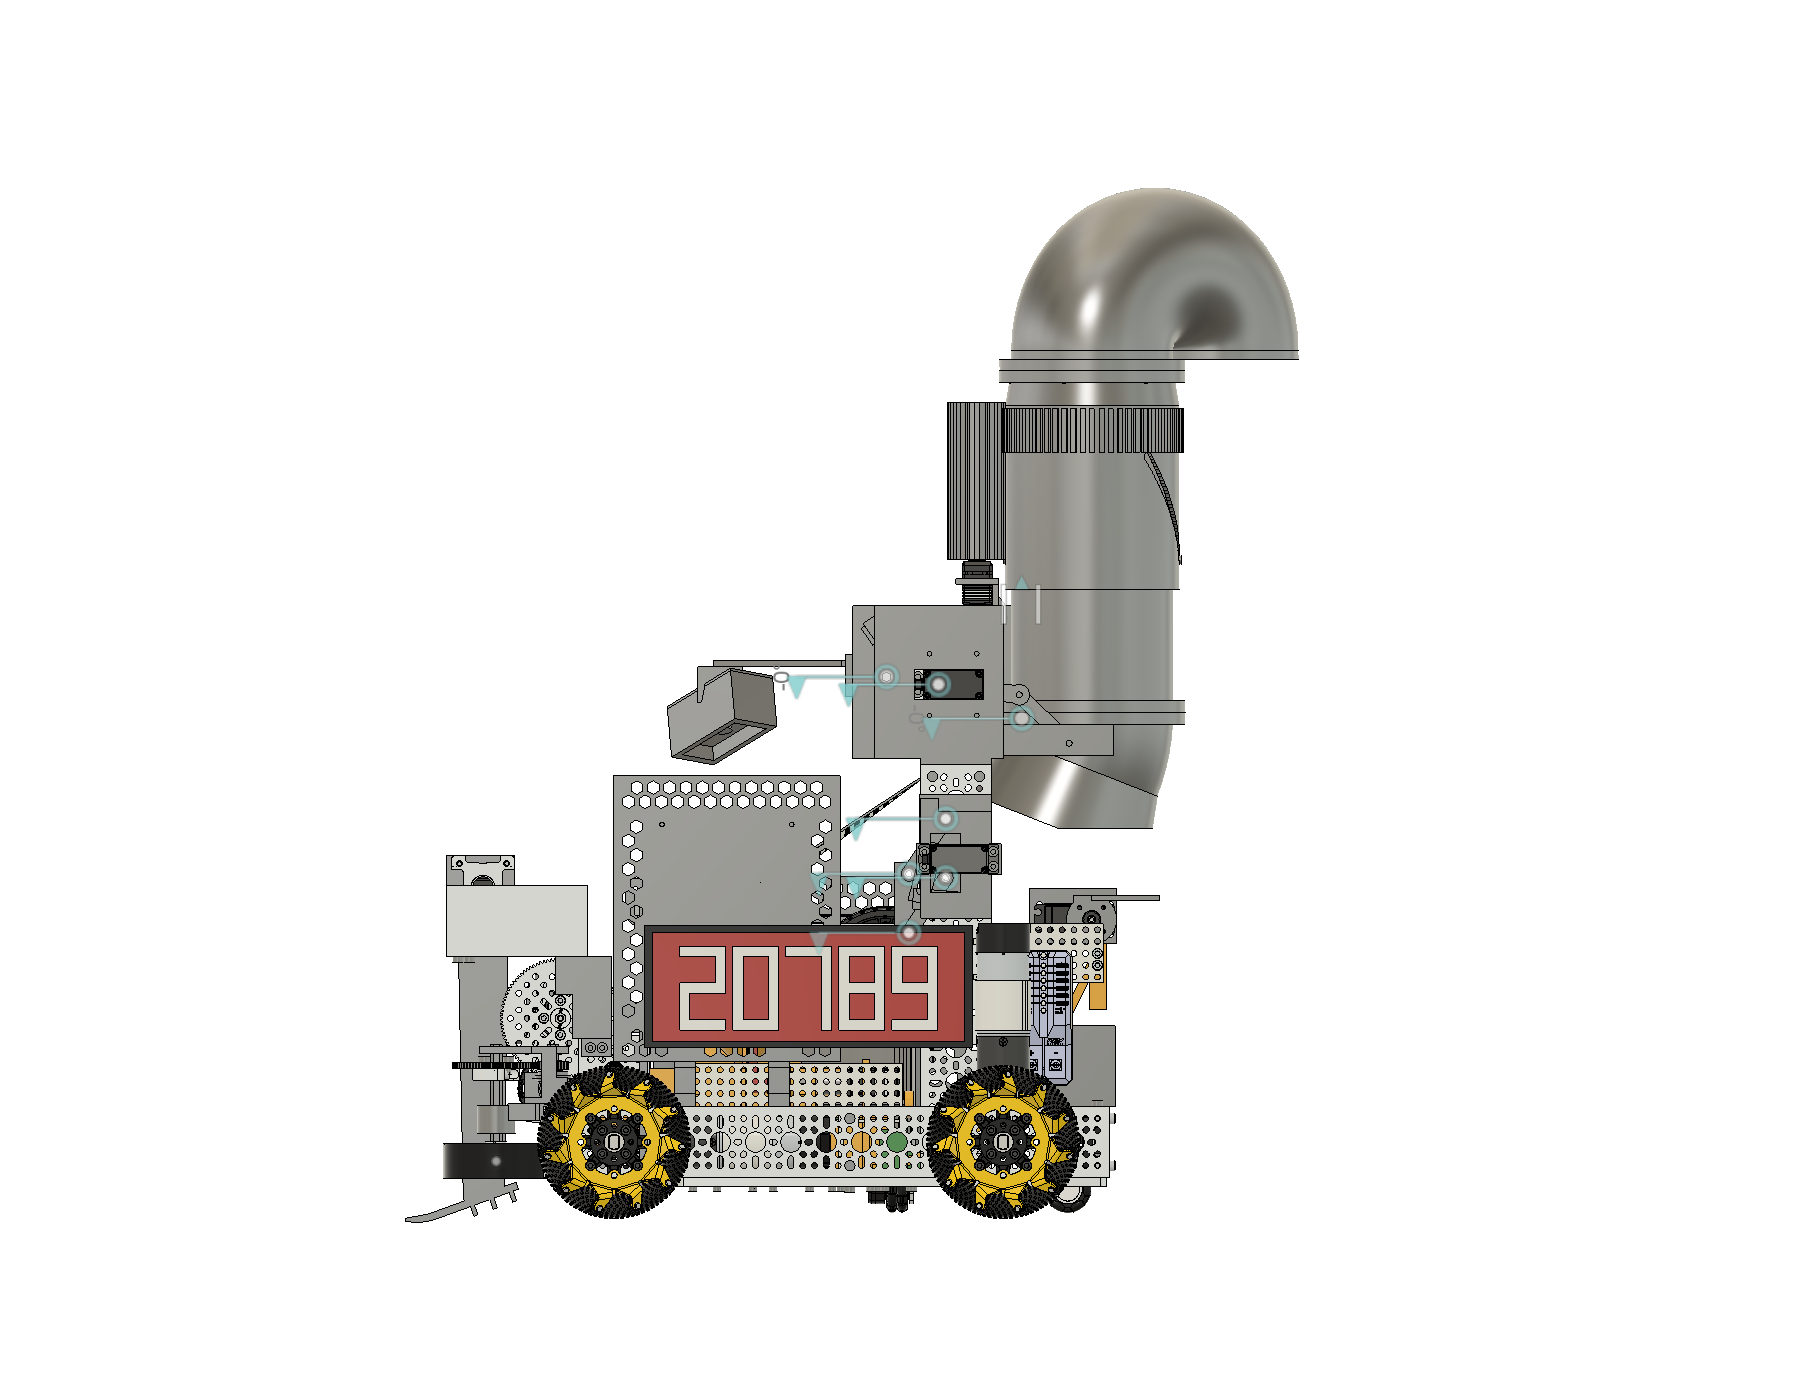
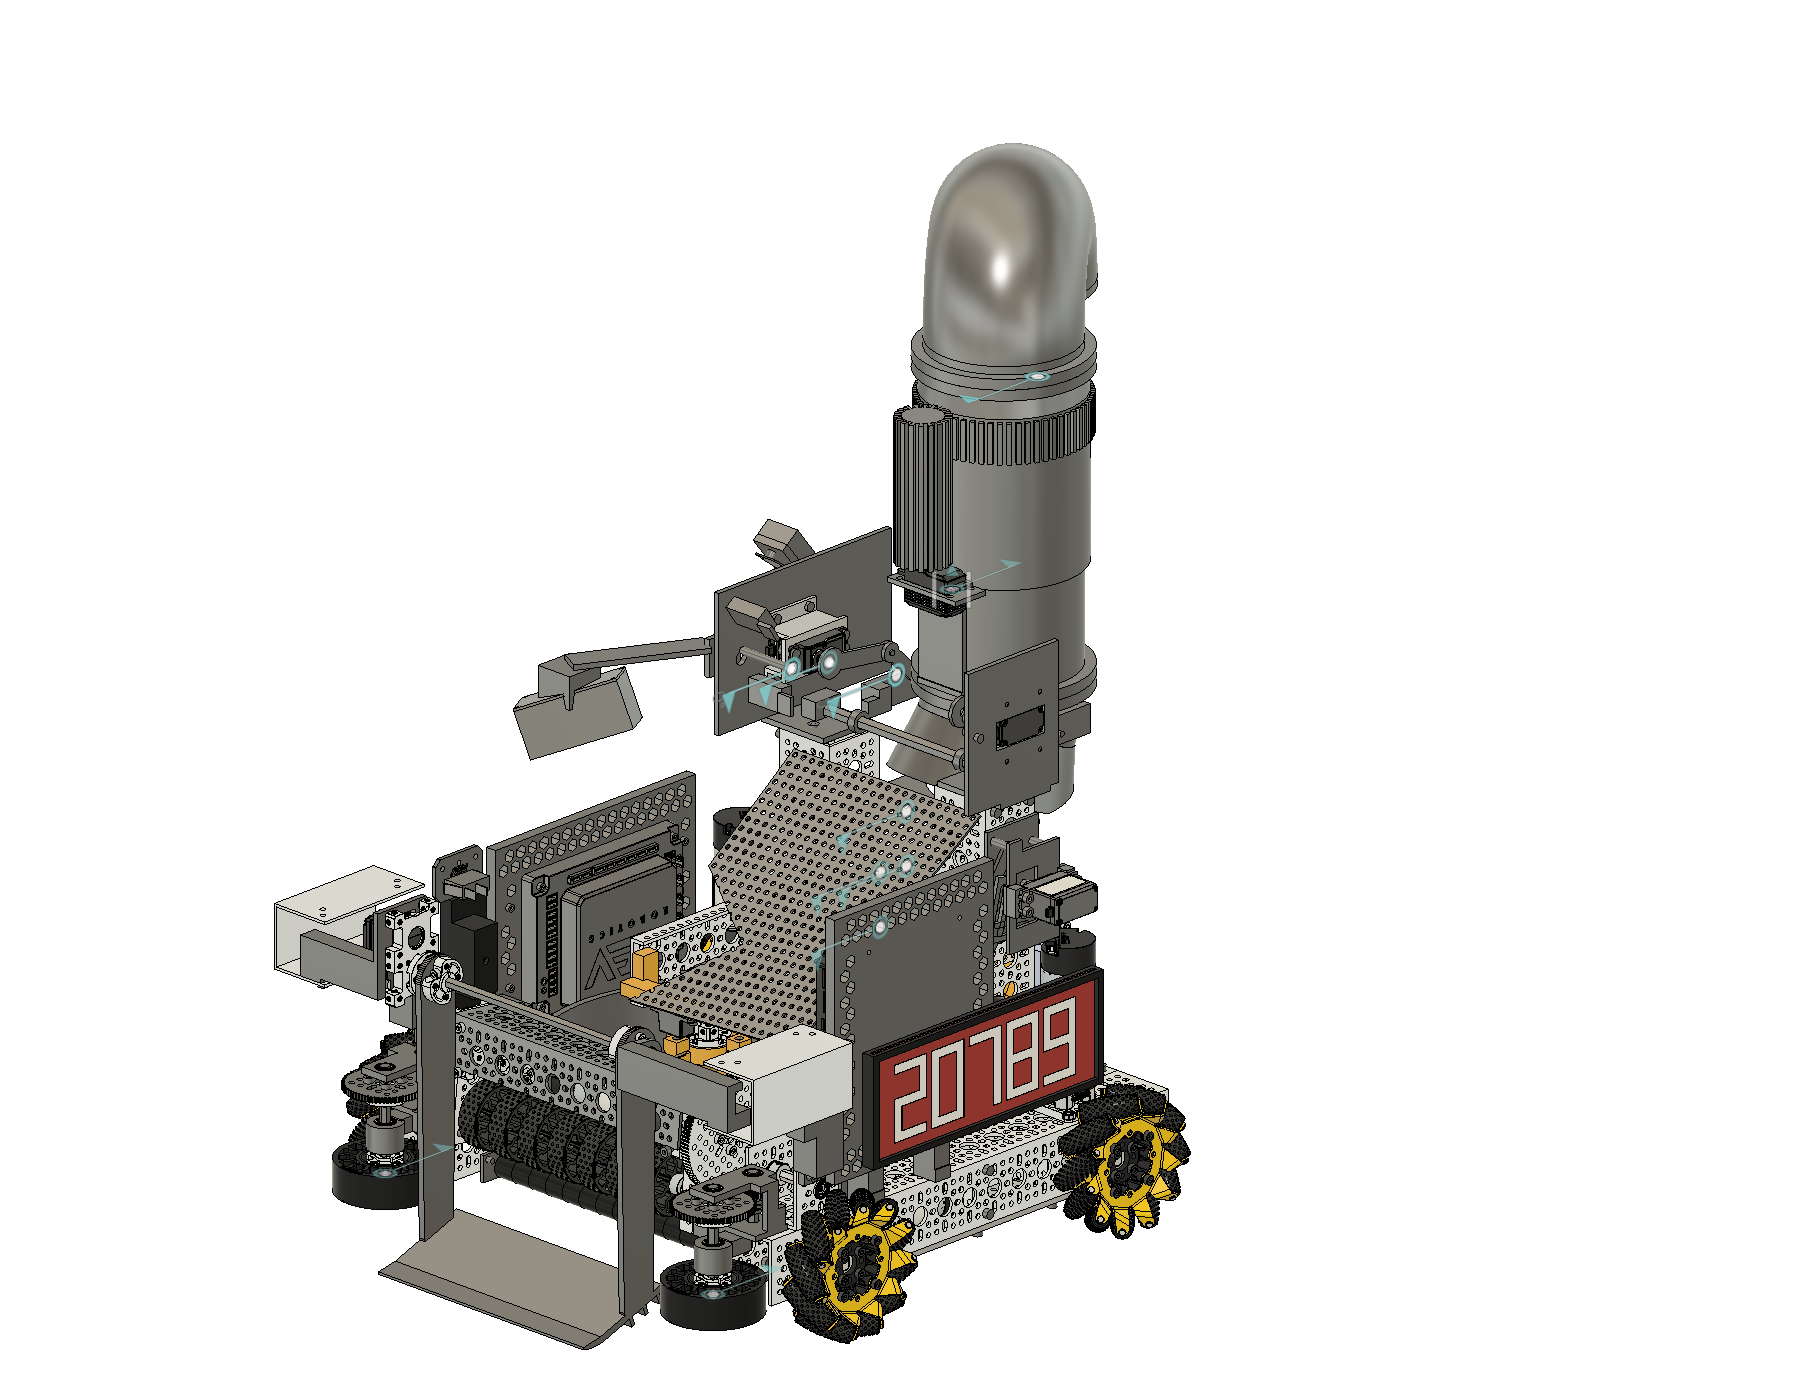
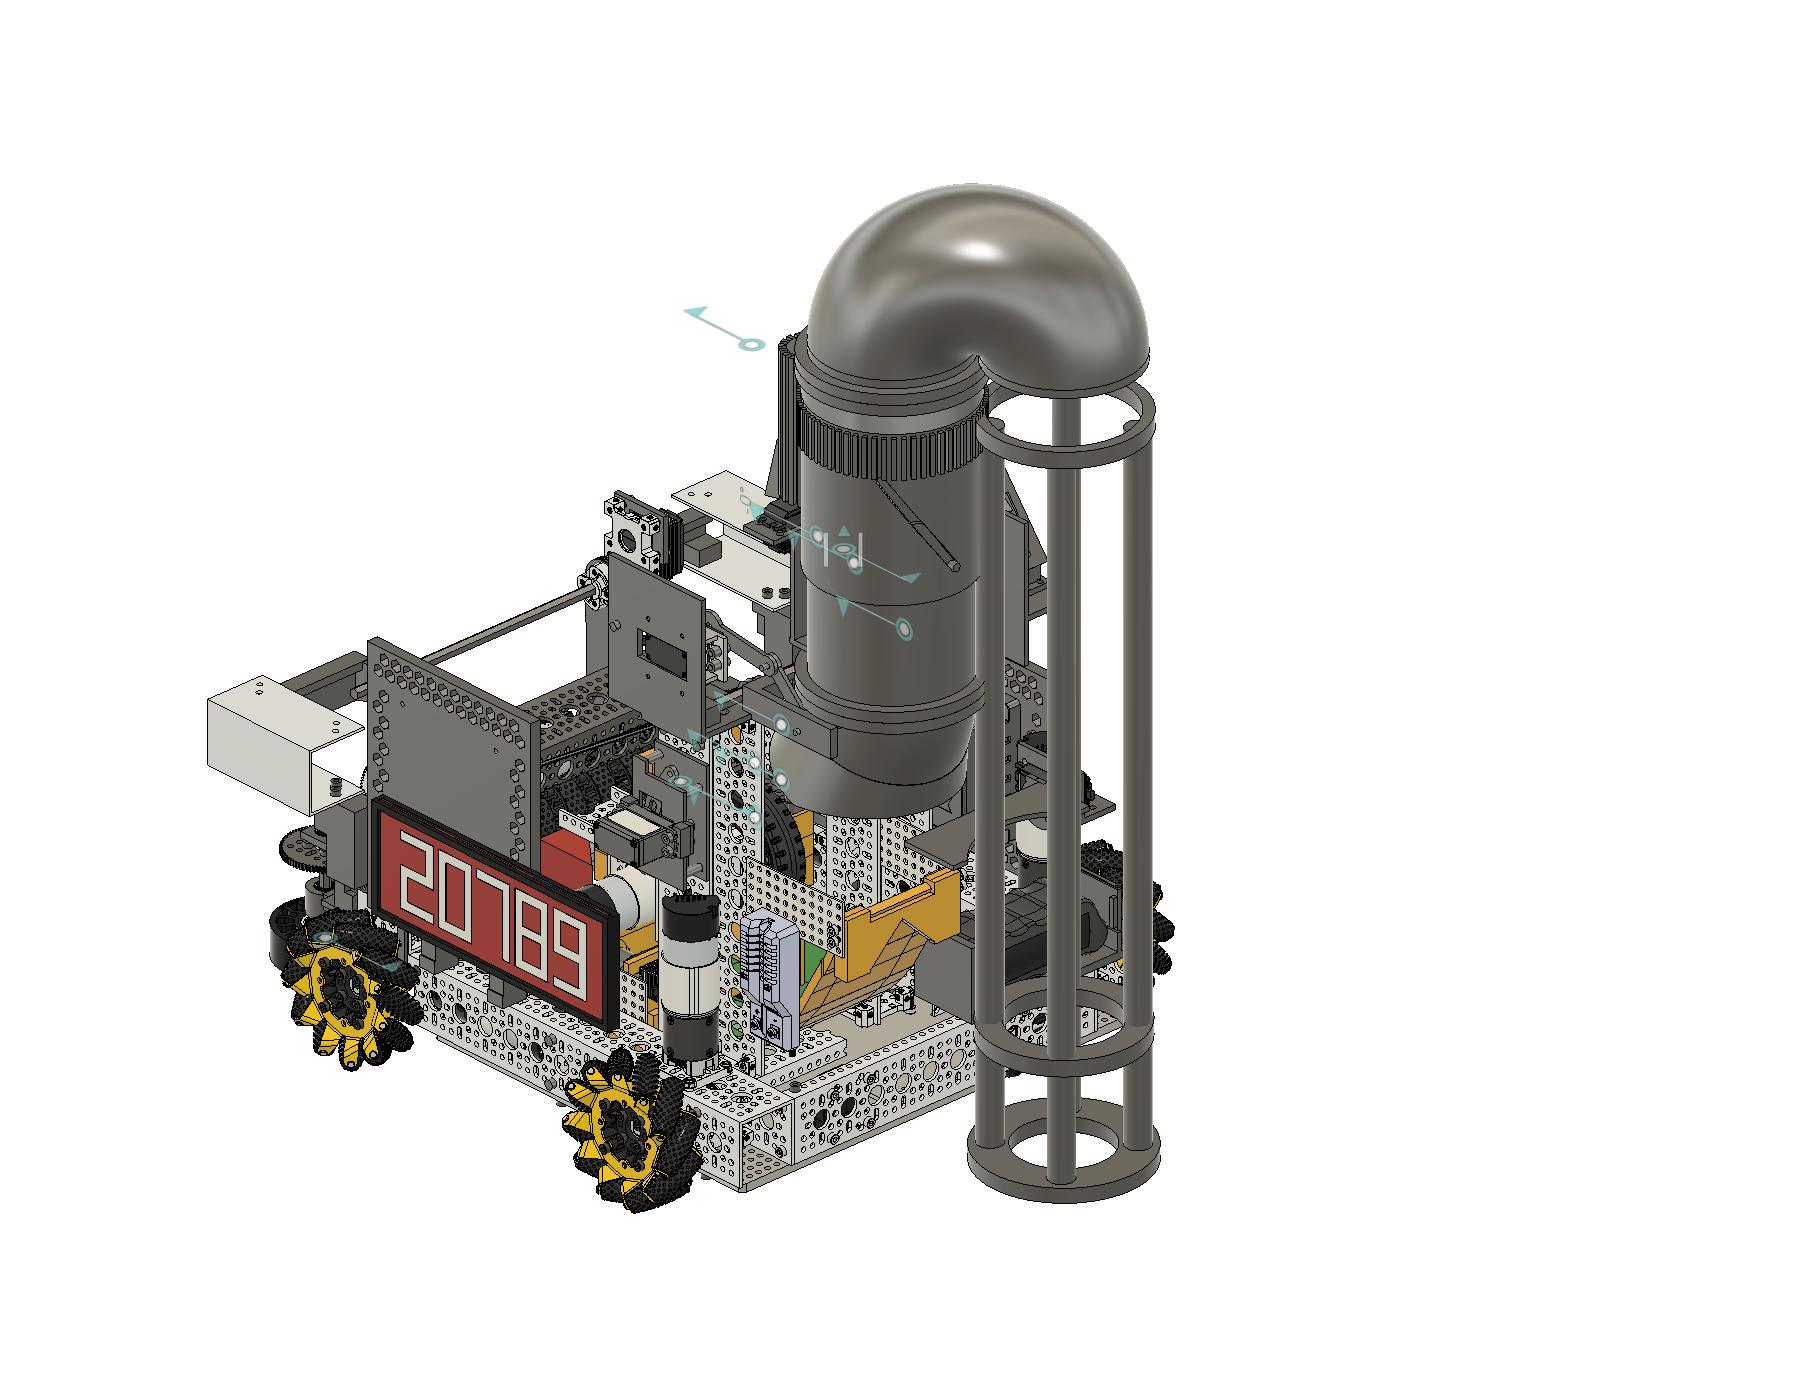
- D3 is a short, wide, slick-walled tube over the rear of the robot. It catches the shot ball and drops it into the FLOWER.
- A passive nest flap with a concave notch sits under the FLOWER pipe cage. It is hinged at the rear top edge and hangs down the rear face when stowed.
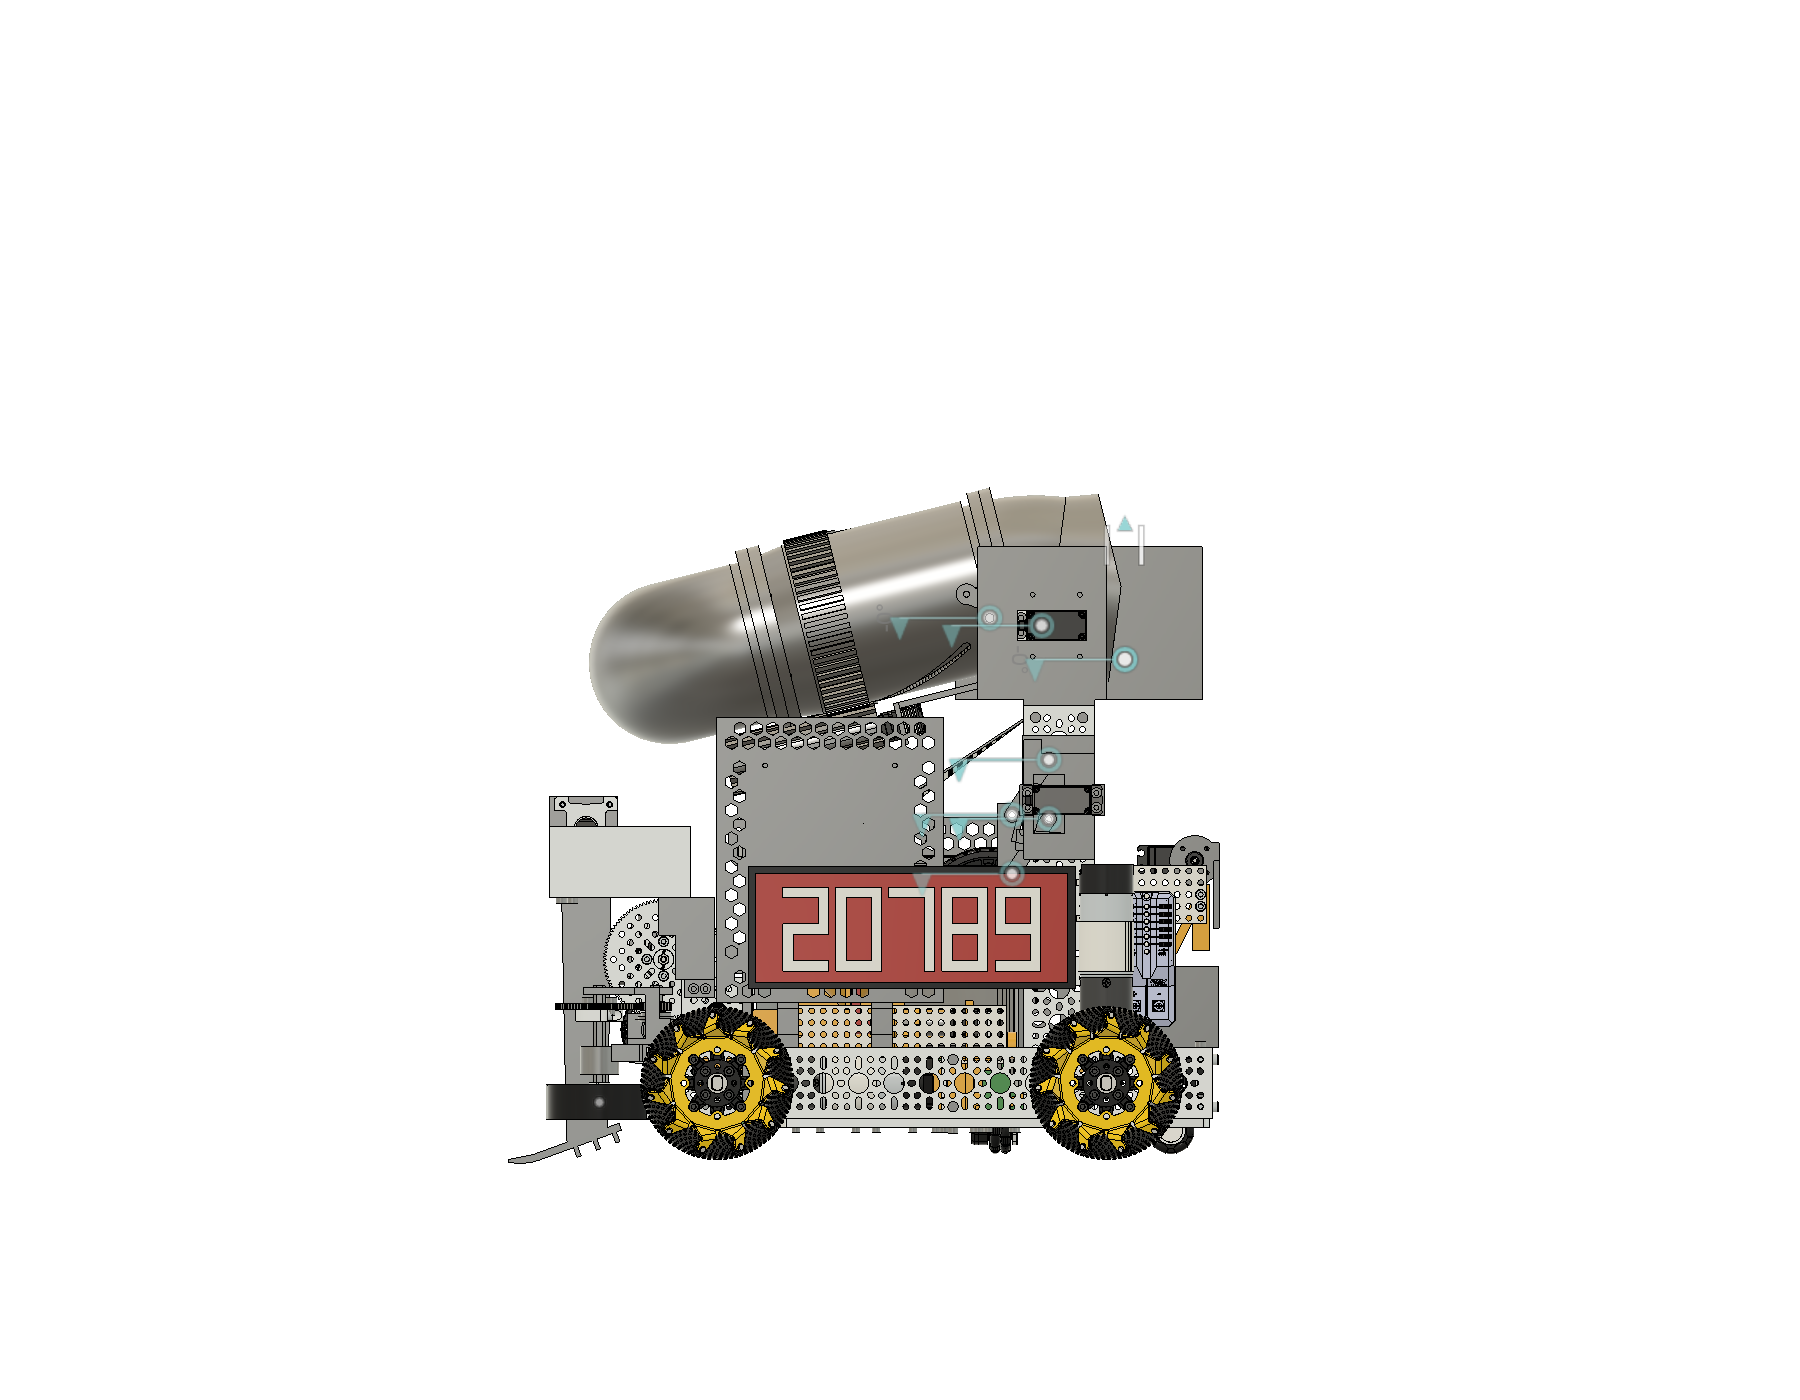
- At fire, the spout rolls 40 degrees toward -x. This keeps the robot inside the 24 in length limit (R105.B). The end of the helical cam slot is the hard stop, so no software interlock is needed.
- One pivot on the tower tops swings the tube 104 degrees forward. The two existing Axon MAX servos drive it through a crank and a link.
- To stow, the tube needs the 90 degree roll plus a 70 mm telescope. Both come from the helical slot, as in V5.
Pictures (D3 first pass, 2026-11-17)
Fusion renders of the first D3 build. D3b and D3c later changed the parts in detail (see below), so small details differ. The wedge is drawn deployed in all of them, as in the model.
Mechanism
| Part | What it is |
|---|---|
| P1 | Funnel plus R100 bend and flange F1 (bore 104). |
| P2 | Fixed inner sleeve, OD 110, with 2 cam pins. |
| Q1 | Slide that goes over the sleeve, so the ball never meets a lip. Has a 60T roll ring, 2 helical slots (50 deg over 70 mm) and a reducer to 104. |
| Q2 | Hairpin bend (R55.5) and spout. Printed in 2 halves. Rolled 40 deg at fire. |
| Roll and telescope | The existing Axon MINI sits at the front of the slide and drives an 18T m2 pinion. Roll 40 to 90 deg and the 70 mm retract come from the helical slot. |
| Lift | Two swing arms on one axle, two cranks on the Axon MAX hubs, two links. D3b: the arms turn on 1611 flanged bearings and the axle is a fixed 192 mm REX shaft in two printed clamps. |
| Nest | Flap hinged at the rear top edge with an R62 notch round the FLOWER pipe cage. Own Axon MINI on a printed carrier. |
Servos: 8 of 8 used (windmill, carriage, blade+gate, wedge, lift L, lift R, roll, nest). There is no spare servo.
Key numbers (CAD, mm)
| Item | Value | Limit or note |
|---|---|---|
| Fire pose, rear / top | y 320.5 / z 647.8 | limits y 349.6 / z 684.6 |
| Length, wedge down, tube at fire | 606.3 | 609.6 (margin 3.3) |
| Tube over the whole 104 deg swing | top max 673.9, rear max 320.5 | inside the R105 limits |
| Stowed margin at the cube top | 1.1 at the P1 flange | tight |
| Fire pose clearance (funnel vs tower) | 3.2 | tight |
| Lift four-bar (D3b) | crank 31.2, link 30.6, 111.6 deg of servo for 104 deg of tube | crank angle -51.5 deg = fire, -163.1 deg = stow |
| Lift servo torque (D3b) | about 1.4 N m needed | 3.33 N m stall at 6 V (2.4x) |
Sim result
The 40 degree rolled hairpin was simulated on 2026-11-17 (source: "D3 roll sim check" in the work order; report flower_compare_2026-11-17/D3_roll_check.md).
- NECTAR 100/100 and POLLEN 100/97, as written in the check. The work order does not say what the two numbers in each pair mean.
- Nest offset +-5 / 10 / 20 mm: 100 / 78 / 29 %.
- Fire at 4.0 to 4.5 m/s, not 5. At 5 m/s the worst POLLEN case drops to 70 %.
- A 35 degree roll would make the tube about 612 mm long, over the 609.6 limit. So 40 degrees stays.
D3b: what was fixed to make D3 printable (2026-11-17)
- The first D3 swing arm hit the lift servo hub and crank at 88 to 104 deg. The four-bar was redesigned so the whole arm is one flat plate outside those parts.
- The pillow blocks could not hold a 14 mm bearing. They were replaced by a fixed REX 192 mm axle in two printed clamps, with a 1611 bearing in each arm and two clamping collars.
- Servo plates were re-made to match the real Axon MINI ear notches. The nest servo now sits on a printed carrier on the left 1117 plate.
- Telescope fit set to 0.4 mm per side. Ball-path joints are chamfered and every step goes down in the ball direction.
- Gate result: 0 FAIL on the printed parts. Several WARN remain and are listed in the build package.
- Tool bug found:
prep_stl.pydid not flip plates set todown:0,0,1. Earlier plates that used it were sliced unflipped. The package names plate 26 (printed 2026-11-15) andv7_rotor_onepieceas the ones to check.
D3c: support-free reprint (2026-11-17)
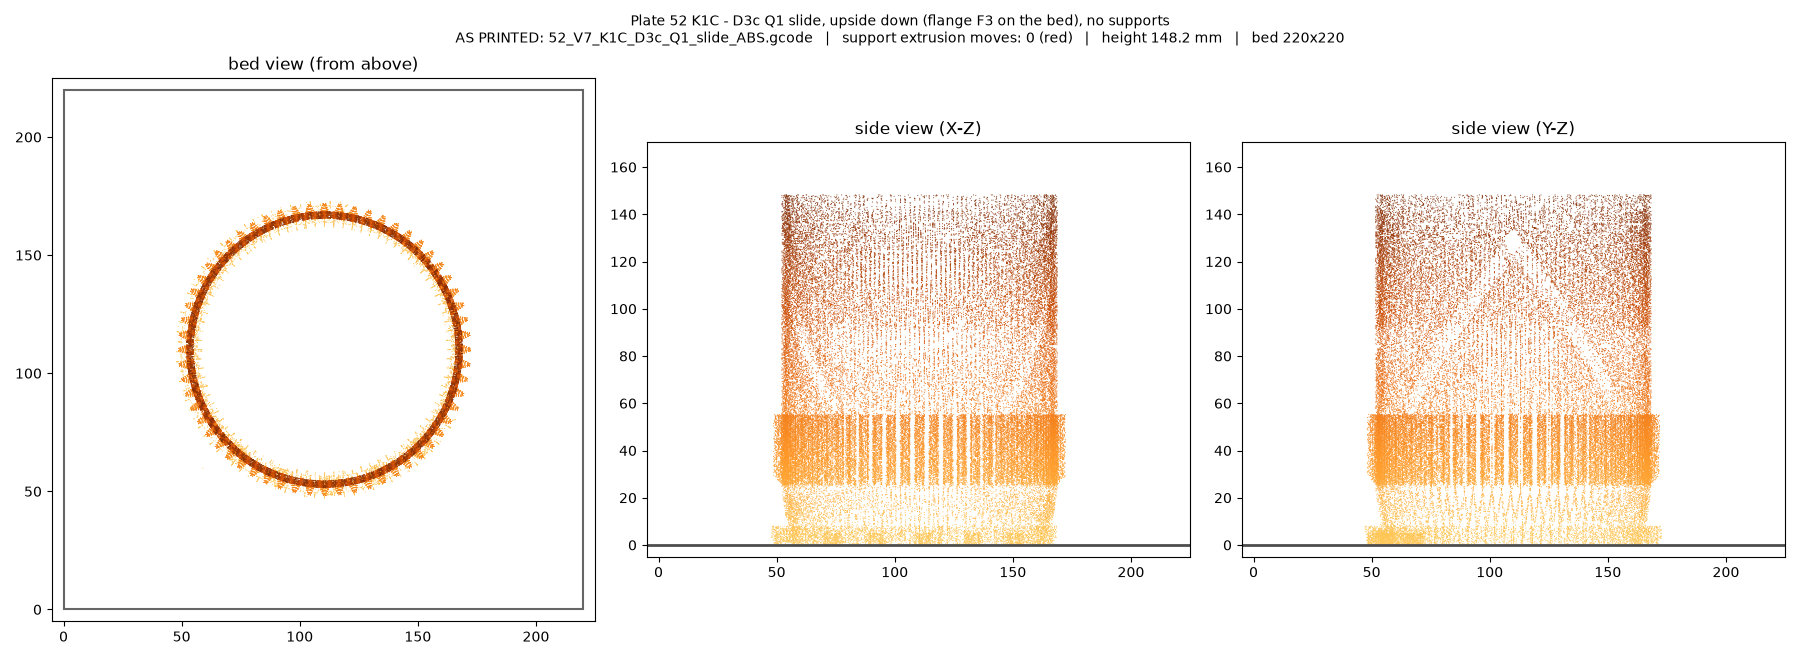
The Q1 tube now prints upside down, with chamfers and teardrop tops at 45 degrees, so it needs no supports. Other parts were re-oriented the same way. Times and weights are Orca estimates. On the P2S, Bambu Studio can show about 2x.
| Plate | Printer | Support moves, before to after | Time, before to after | Grams, before to after |
|---|---|---|---|---|
| 50 P1 + pinion | P2S | 32,582 to 0 | 7h15 to 5h26 | 176 to 150 |
| 51 P2 sleeve | K1C | 295,008 to 0 | 5h57 to 4h04 | 191 to 149 |
| 51b roll bracket | K1C | needs supports (200,478) | 1h34 | 38 |
| 52 Q1 slide | K1C | 1,709,325 to 0 | 11h57 to 7h03 | 260 to 180 |
| 53 Q2 half A | P2S | 61,739 to 45,240 | 6h09 to 5h27 | 132 to 122 |
| 54 Q2 half B | P2S | 87,932 to 69,842 | 7h25 to 6h38 | 150 to 139 |
| 55 arms, cranks, links, clamps | K1C | 0 (unchanged) | 1h47 | 35 |
| 56 flap + carrier | K1C | 79,154 to 0 | 2h23 to 2h01 | 54 to 52 |
Not support-free: the Q2 hairpin halves (plates 53 and 54) and the roll servo bracket (51b). A bent tube has no print direction without a lower cylinder surface. A support-free hairpin needs a design change.
Sunday 2026-11-22 build (outline)
- Bench checks: measure a real FLOWER pipe cage, the Axon MINI ears and the 1908 hub hole pattern. Fit the slide on the sleeve dry.
- Shelves: remove two camera screws, then drill and tap the clamp holes.
- Heat-set inserts, then tube assembly, then the lift axle, arms, cranks and links.
- Hand-cycle 0 to 104 degrees with the wedge down before any power.
- Nest carrier, servo and flap. Then drop tests with NECTAR and POLLEN at roll 40.
Not verified
- The ball path with the 40 degree rolled hairpin has not been tested on a real printed part. The sim is the only evidence.
- The 1908 hub is still marked "provisional, do not order yet" in the BoM. Check the bin.
- Margins are tight: link to P1 1.4 mm at stow, right arm to shelf corner 1.4 mm, axle bottom flat 0.6 mm over the shelf.
- The arm-to-tube joint is one clamped M3 lug per side. Watch for creep.
- The FLOWER pipe cage size is assumed (4 pipes, OD 19). Measure a real one.
- Q2 is held to Q1 by 5 screws, all in half B. Half A is held only by the acetone weld.
- Camera: the current Fusion camera angle (53 deg) cannot see tags below 31.5 deg. The build package recommends a fixed mount near 30 deg, but it is not designed.
- The pictures above show the first D3 pass, not the D3b or D3c parts.
The older FLOWER tube study (V5 four-bar tube) is kept on the FLOWER tube (old) page.